Explore an episode
Switch cameras, move through decisions, and inspect generated annotations beside the footage.
Open the studio ↗Datumwell / Embodied-agent data / v1.0
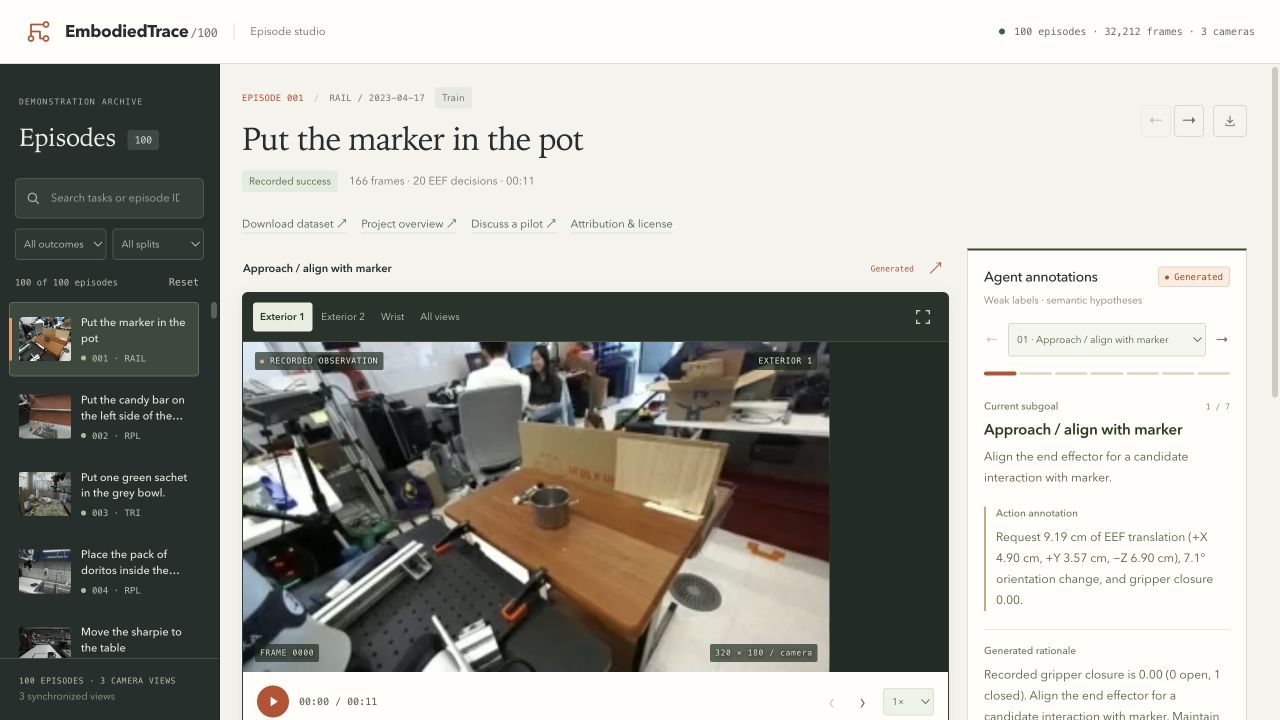
See the task.
Explore the subgoal.
Read the action.
Visual observations, task-oriented annotations, and structured robot actions — together in an inspectable 100-episode sample.
For teams exploring data representations for embodied agents.
A concrete starting point
Start with the example. Inspect the observations, read the generated subgoal, and compare the structured action with your own interface.
Task
Put the marker in the pot
Subgoal · generated
Approach / align with marker
Recorded-command action label · abridged
move_eef(position_m=[0.432, 0.109, 0.481],
quaternion_xyzw=[−0.988, −0.034, −0.117, 0.091],
gripper_closure=0.0)
An end-effector (EEF) pose action describes a target position and orientation for the robot's working end, alongside a gripper command. This example is rounded for display; the dataset retains full precision.
Three ways to inspect
Switch cameras, move through decisions, and inspect generated annotations beside the footage.
Open the studio ↗Load one decision before downloading media. The dataset card includes a short Python example.
Read the dataset card ↗Discuss your task coverage, observation inputs, action representation, and annotation needs.
Discuss a pilot ↗Your tasks. Your action format.
Share the problem you're working on. We can discuss a scope, sample format, and evaluation criteria before any engagement.
Discuss your data requirements ↗Prepare a pilot brief → A checklist to share with your team.
Useful starting points for the conversation
Before you evaluate
Subgoals, concise rationales, and action descriptions are generated labels for inspection. They are not recorded human thoughts or verified task completion. Original observations and recorded-command action labels remain distinguishable in the package.
The sample uses robot-base end-effector pose targets. Your team should assess embodiment compatibility and an appropriate action adapter. The derived sparse targets have not been separately executed; no robot-performance improvement is claimed.
The dataset package contains 4,081 decision rows across episode-level splits, a schema, and optional original JPEG/video archives. The studio's per-episode JSON download is an inspection export, rather than the training package.
The 100 episodes provide a representation sample, not a claim of production coverage. Read the coverage summary and bring your required tasks, inputs, and annotation criteria to a scoping discussion.
Talk to Datumwell
Tell us the tasks, action format, and annotation needs your team wants to explore. We can discuss a sample scope and review criteria.
Copy our email, select it for manual copying, or open your email app.